 2 Geeks Web Design
Category Archives: The Legs
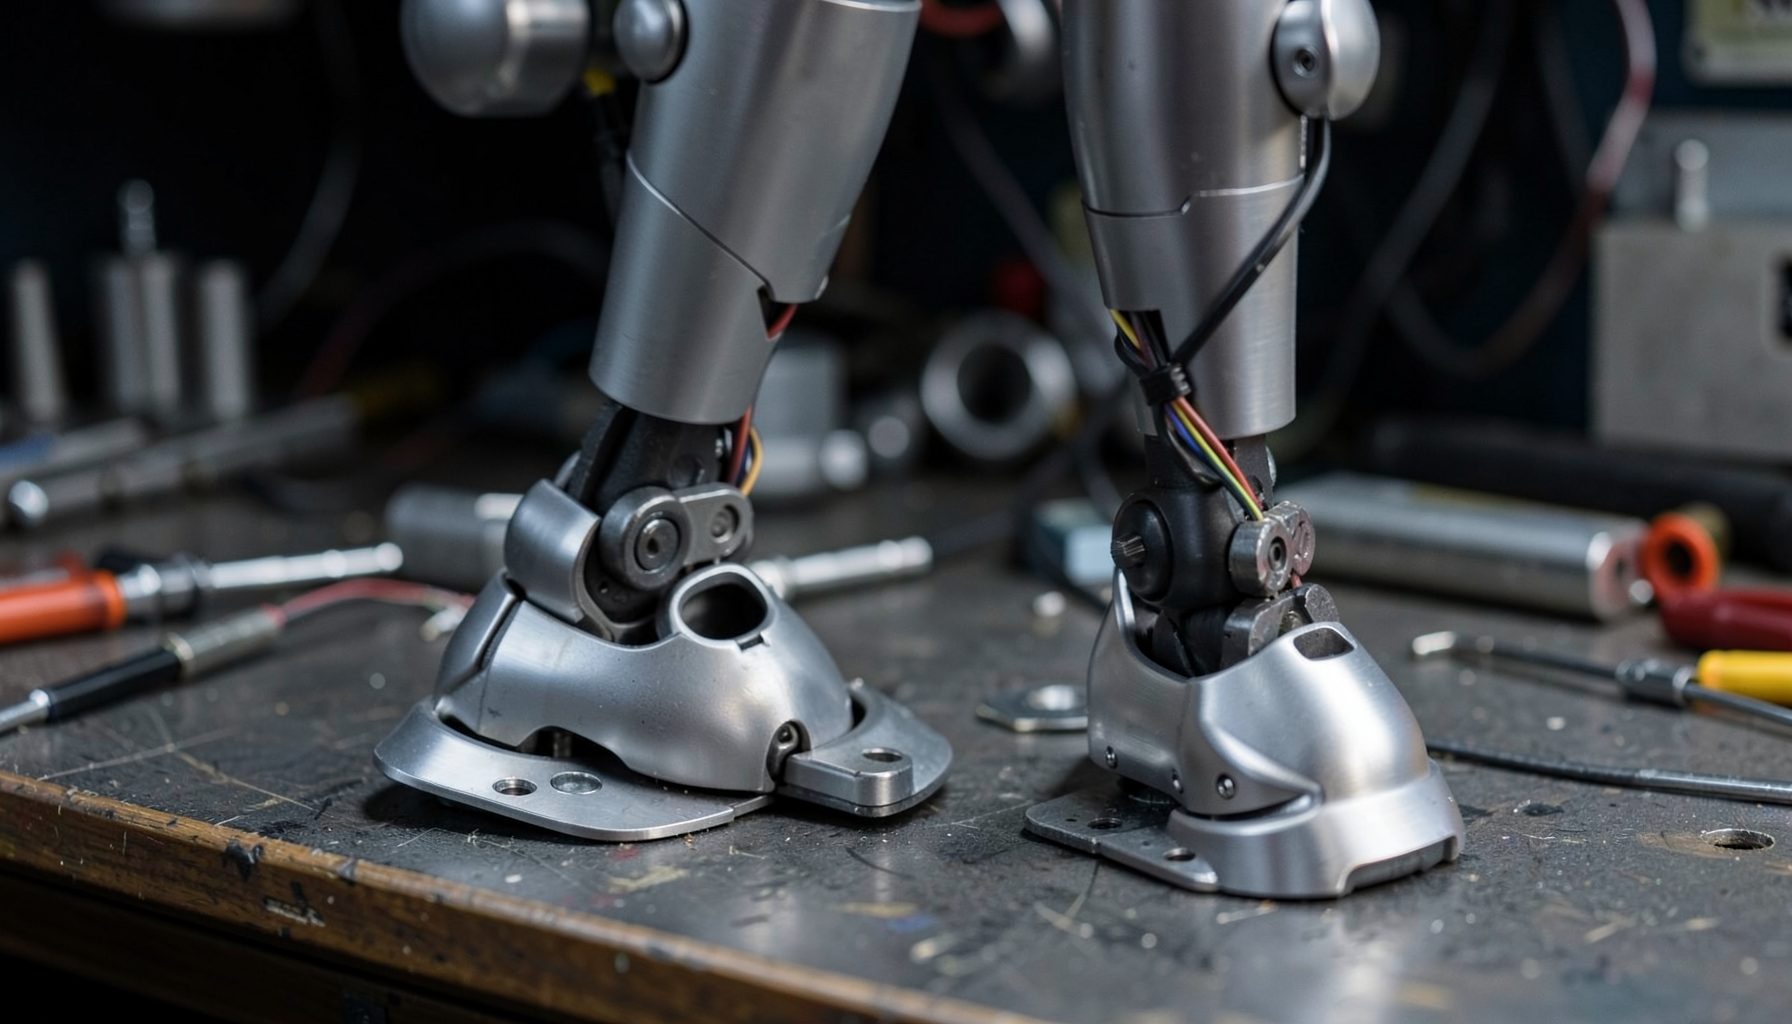
A collection of build posts related to the construction and design of our Astromech's three legs and propulsion.
Legs & Propulsion
The leg subsystem is where locomotion comes together. This category tracks the assembly and testing of all three legs — two shoulder legs and one center leg — along with the drive electronics that bring the droid to life.
- Differential drive system using scooter motors for independent wheel control
- Pololu Simple High-Power 18v25 motor controllers for the foot drives
- RC-based control for steering and throttle via a standard transmitter
- Midwest R2 Builders Club DDR Foot Drives as the mechanical foundation
The build posts below document everything from initial motor-controller prep through the first successful drive test under radio control.
Build Posts
December 25, 2013
Artoo's First Steps: Testing His Differential Drive System via RC
The first drive test under radio control. With the Pololu 18v25 controllers wired to the scooter motors and bound to the RC transmitter, the differential drive system got its maiden run — a milestone moment in the build.
December 17, 2013
Testing My Syren 10 and Pololu 18v25 Motor Controllers with Drive Motors… I Went 2-3 with a Huge Strike Out!!
A candid bench-test session. The Syren 10 (for dome rotation) and Pololu 18v25 controllers (for foot drives) were wired up and run against the drive motors. Not every test went smoothly, but the troubleshooting yielded valuable insights.
December 2013
Prepping My Pololu Simple High-Power 18v25 Motor Controllers
Before the drive tests could begin, the Pololu 18v25 motor controllers needed preparation — soldering connectors, configuring current limits, and planning the wiring layout for the foot drive assemblies.
November 25, 2013
Figuring it all Out!
The very first build post. Ryan lays out the initial research, the decision to use a differential drive approach with scooter motors, and the early planning that would shape the leg and propulsion design.
Building the legs of an astromech droid is where the project truly starts to feel alive. Each leg in this build serves a distinct purpose, with the two shoulder legs providing balanced support and the center leg adding stability and maneuverability. The propulsion system relies on a differential drive arrangement that gives the droid independent control of each wheel, allowing for smooth turns and precise movement in tight spaces. Motor controllers handle the power delivery to the foot drives, while a standard RC transmitter gives the operator intuitive steering and throttle control. This category documents the iterative process of assembling, wiring, and testing the locomotion subsystem, from the initial frame construction to the final tuning of the drive electronics that make the droid roll.
Key Components in the Leg System
The differential drive system uses two independently controlled scooter motors mounted in the foot shells, governed by the Pololu 18v25 controllers. Steering is achieved by varying the speed of each motor — a setup well-documented by the Midwest R2 Builders Club and refined through community collaboration on Astromech.net.
Explore Related Sections
- Build Journal — the full chronological timeline of all build posts
- The Electronics — motor controllers, RC configuration, and dome lighting
- Parts Rundown — complete parts list with sources for every subsystem